Motion Compensation
X-Wave™ provides a flexible motion compensation platform for marine and offshore equipment, delivering Active Heave Compensation, constant tension control and platform stabilisation across new-build and retrofit applications. Designed to work with electric and hydraulic machinery, the system combines self-learning control, configurable operating modes and modular integration to improve the control of equipment operating from moving vessels.
System Overview
X-Wave™ Universal Motion Compensation
X-Wave™ is designed to add accurate motion compensation to a wide range of offshore machinery without requiring a different control platform for every application. It can support Active Heave Compensation of ROV, AUV and trencher LARS, subsea cranes, lift winches, deep-water lowering systems, well intervention and IMR equipment, as well as stabilisation of lifting, helideck, antenna and personnel-access platforms.
The platform can control rotary and linear actuators driven electrically or hydraulically and can be deployed as a dedicated stand-alone controller or integrated into an existing or new machinery-control architecture. Self-learning functionality continually adapts to changing vessel motion and machine characteristics, reducing the amount of application-specific configuration required.
Who this is for Offshore contractors, vessel operators, subsea equipment manufacturers, ROV and trencher operators, crane and winch OEMs, IMR teams and engineering organisations requiring motion-compensated offshore handling or access systems.
Key Features
One Motion Control Platform Across Multiple Applications
X-Wave™ combines self-learning control, multiple operating modes and a modular architecture within a standardised system that can be adapted across different vessels, machines and actuator technologies.
Self-Learning Control
X-Wave™ continually measures and adapts to changes in vessel motion, machine behaviour and system dynamics, reducing dependence on vessel-specific calibration and setup.
Multiple Machine Control
A single X-Wave™ system can control multiple items of deck equipment, supporting wider utilisation of the control platform across an offshore equipment spread.
Multiple Operating Modes
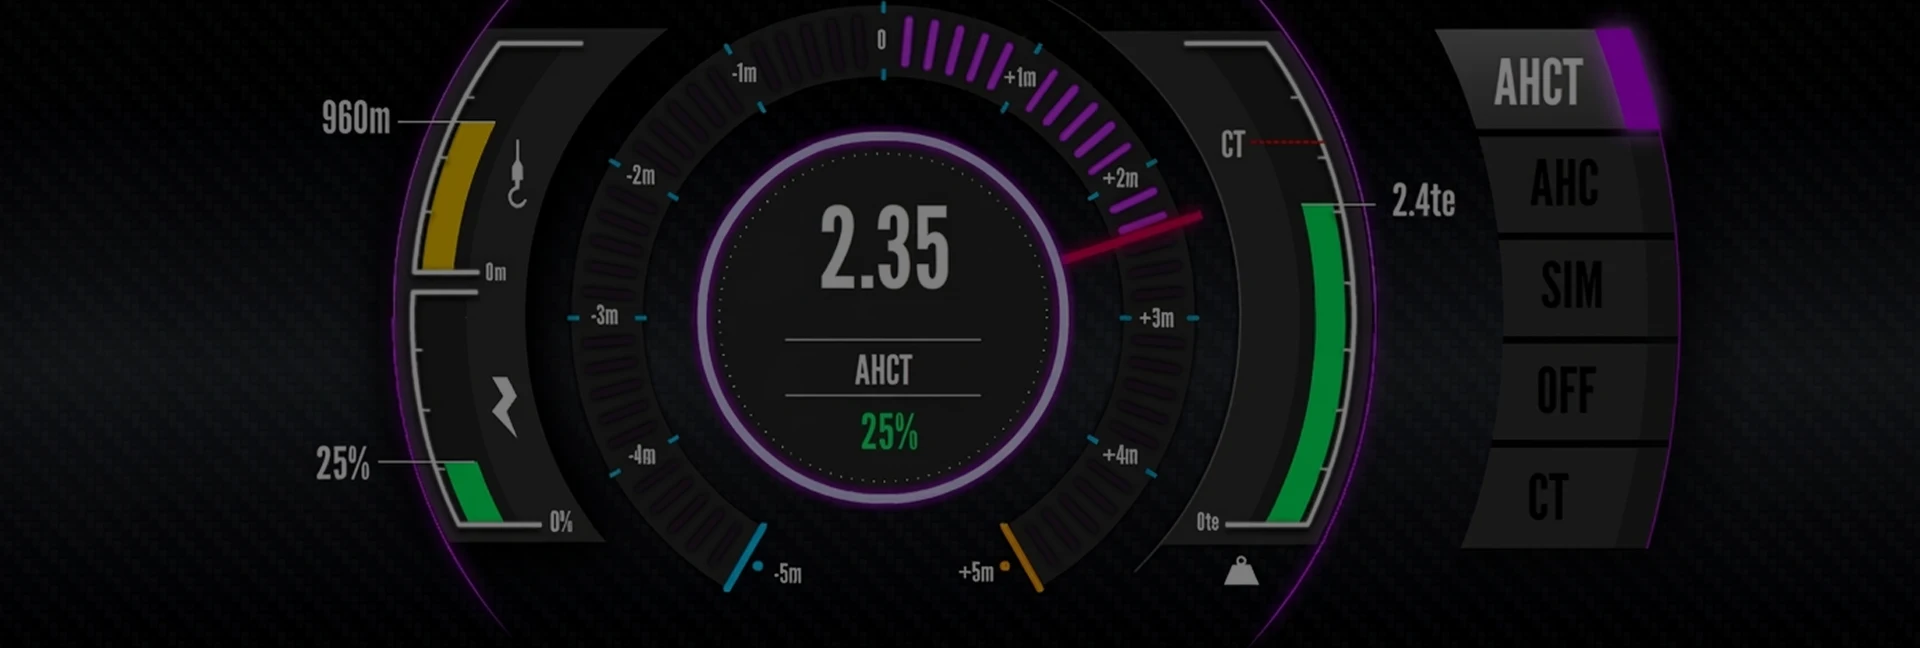
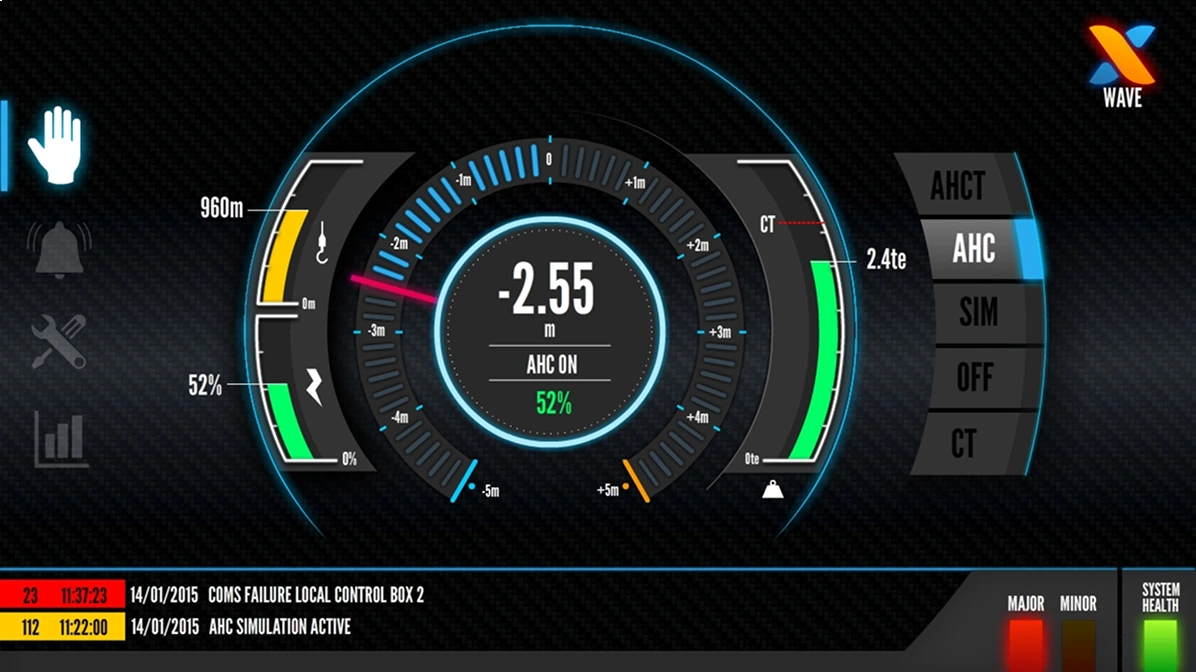
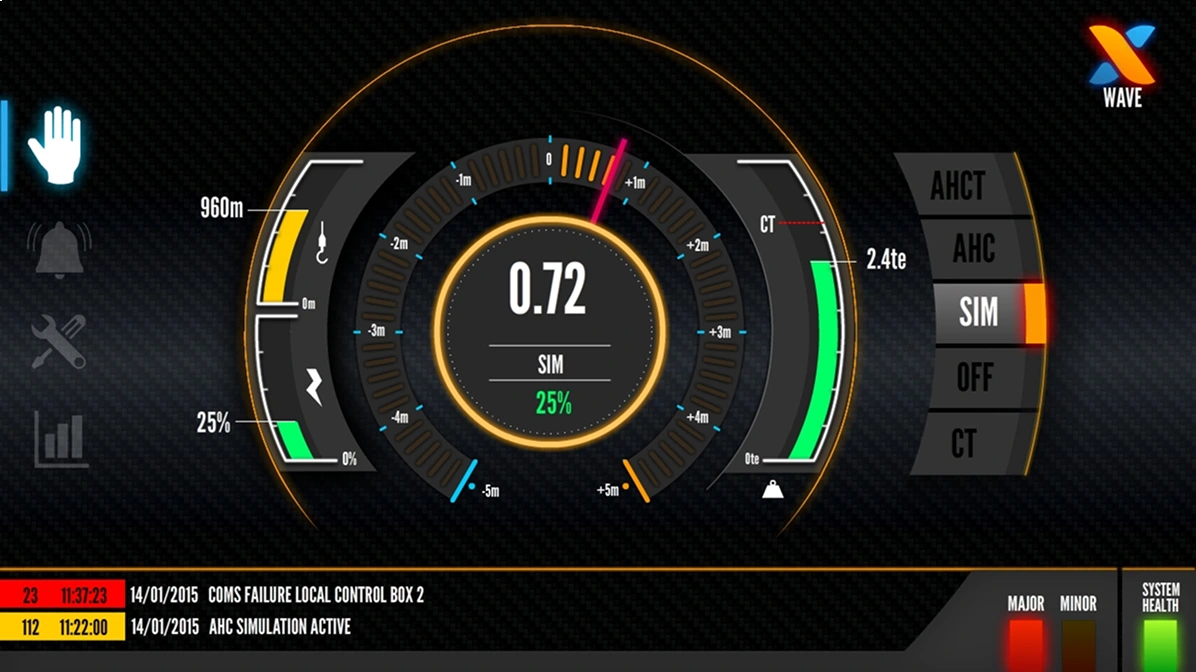
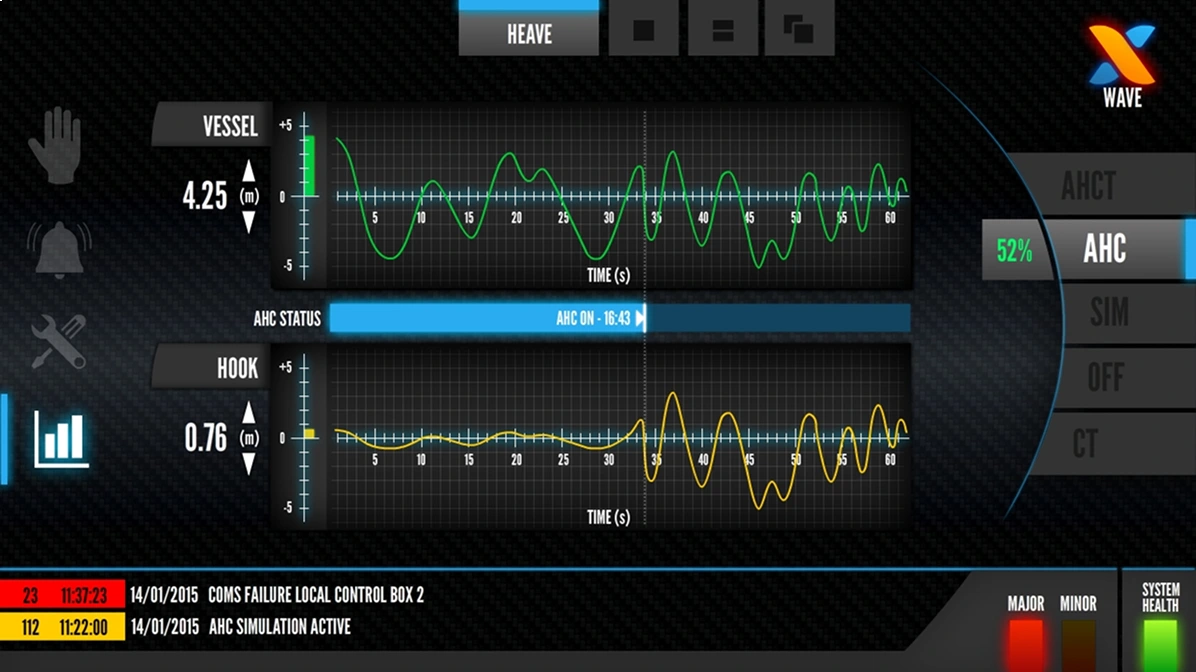
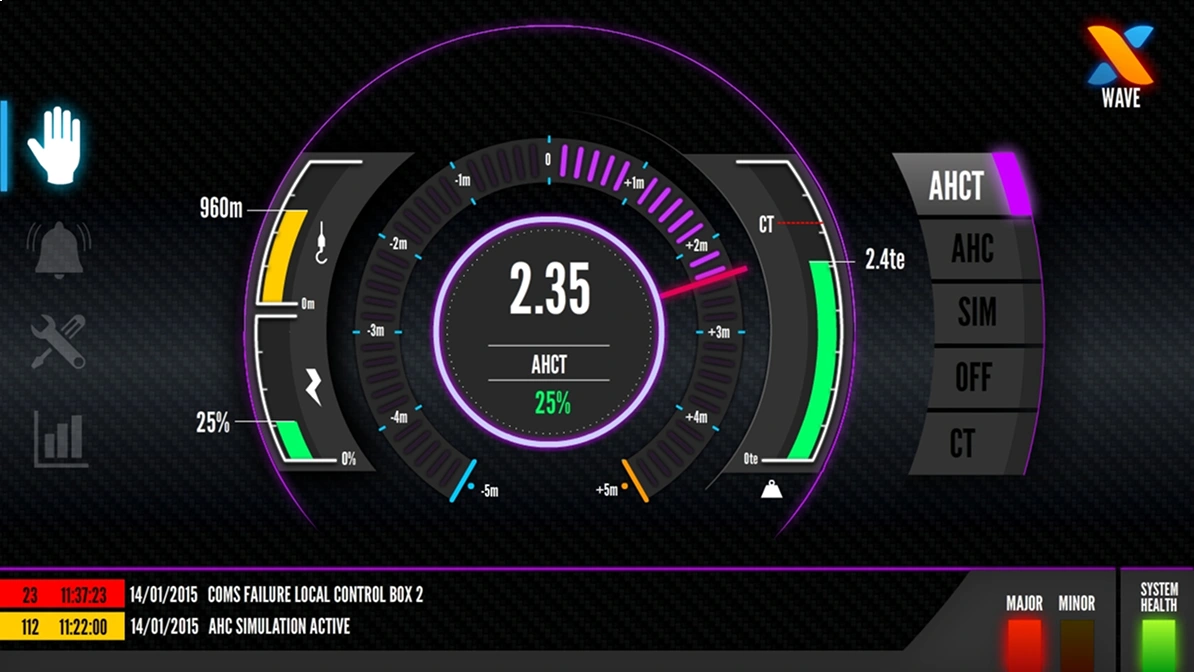
The system supports Active Heave Compensation (AHC), Constant Tension (CT), combined AHC + CT (AHCT) and simulation functions for assessing expected compensation performance.
Modular & Cross-Platform
X-Wave™ can run on dedicated real-time controllers, industrial PLCs, PCs, microcontrollers or be integrated directly into electric variable-speed-drive firmware and application software.
Operational Benefits
Designed to Simplify Offshore Motion Compensation
The X-Wave™ platform is designed to reduce the engineering and configuration normally associated with application-specific motion compensation while giving operators clear control, diagnostics and system visibility during offshore operations.
Easier to Operate
A clean operator interface presents operational information without unnecessary complexity, supported by diagnostic and data-logging functions.
Faster Configuration
Wizard-based setup and more than 300 configurable alarms, inputs, outputs and internal variables allow systems to be configured without rewriting the underlying software.
High-Integrity Control
Critical functions can be deployed with redundant architecture, including duplicate X-Wave™ cores for demanding applications.
Remote Support
Diagnostics can be accessed remotely through the vessel's VSAT connection, supporting fault investigation and technical assistance without always requiring onboard attendance.
Operating Modes
Control Modes for Different Offshore Operations
X-Wave™ provides several operating modes within the same control platform, allowing the system to respond to different lifting, lowering, tensioning and commissioning requirements without requiring separate motion compensation solutions.
- Active Heave Compensation — AHC Compensates for vessel heave by controlling the lifting or handling equipment in response to vessel movement, helping maintain the required position of the suspended equipment or load.
- Constant Tension — CT Controls the equipment to maintain the required line or cable tension during an offshore handling operation.
- Combined AHC + CT — AHCT Combines heave compensation and tension control where the application requires both position compensation and controlled load behaviour.
- Simulation Mode Allows expected motion-compensation performance to be evaluated against prevailing conditions before or during system setup.
Applications
Where X-Wave™ Motion Compensation Is Used
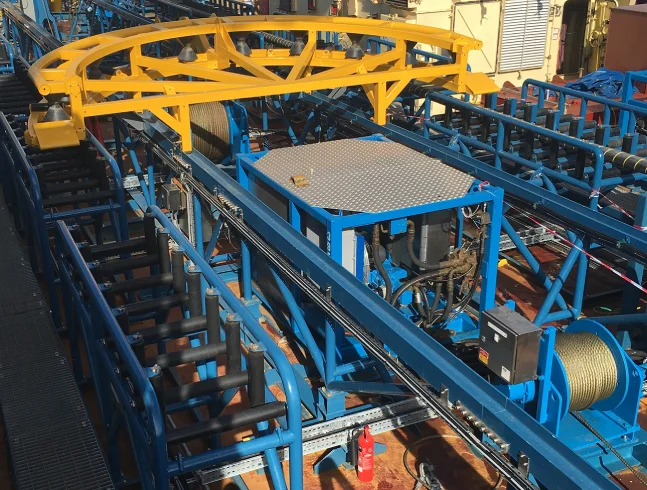
The modular architecture allows X-Wave™ to be applied across offshore lifting, subsea deployment, intervention, handling and stabilisation systems, from individual winches and cranes through to more complex multi-axis equipment.
- ROV, AUV & Trencher LARS Active heave compensation for launch and recovery systems where controlled deployment, docking and recovery are affected by vessel movement.
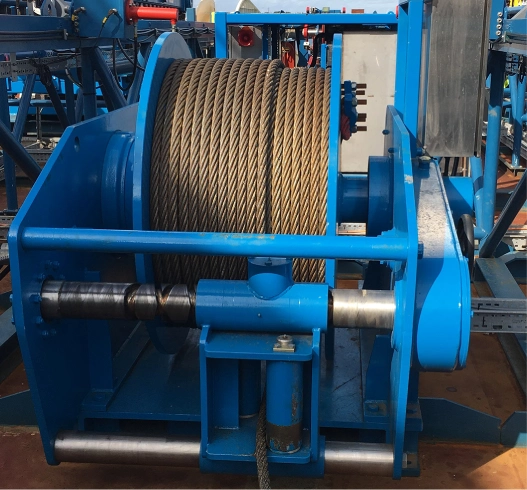
- Subsea Cranes & Lift Winches Motion compensation for offshore cranes, winches and deep-water lowering systems where accurate load control is required during subsea operations.
- Well Intervention & IMR Equipment Control for well intervention, inspection, maintenance and repair systems, IWOC equipment, drill-string compensators and flying-sheave systems.
- Platform & Access Stabilisation Multi-axis stabilisation applications including lifting platforms, helidecks, antenna systems, walk-to-work equipment and personnel-access systems.
How It Works
From Vessel Motion to Compensated Machine Movement
X-Wave™ combines vessel-motion information with real-time machine and process data to determine the compensation required from the connected equipment. Its self-learning control continuously adapts to actuator response, load changes and changing vessel dynamics, commanding the electric or hydraulic machinery to counter vessel movement while providing operators with live control, diagnostics and data logging.
Step 001
Measure Motion
Motion-reference data identifies vessel heave and other relevant movement while the system monitors the behaviour of the connected equipment and process.
Step 002
Learn the Machine
Self-learning routines identify equipment characteristics such as actuator response, acceleration limitations, inertia and system delays rather than relying solely on extensive manual tuning.
Step 003
Calculate Compensation
The real-time control system determines the machine movement required to counter the measured or predicted vessel motion according to the selected operating mode.
Step 004
Control the Actuator
X-Wave™ commands the connected electric or hydraulic actuator, whether a rotary winch, linear cylinder or other compatible motion-control arrangement.
Step 005
Adapt, Monitor & Record
The platform continually adapts as vessel or machine behaviour changes while diagnostics, data logging and operator interfaces provide visibility throughout the operation.
Technical Specifications
Structured information for technical evaluation
X-Wave™ is a configurable motion-control platform rather than a single fixed machinery package. Final system architecture depends on the machine, vessel, actuator, control-system interfaces, redundancy requirements and required motion-compensation modes.
- System type Universal offshore motion compensation control system
- Operating modes AHC, CT, AHCT and Simulation
- Actuator types Rotary and linear
- Drive technologies Electric and hydraulic
- Configuration 300+ configurable alarms, inputs, outputs and internal variables
- Control platforms Real-time controller, microcontroller, PLC, PC or embedded drive control
- Architecture Modular, stand-alone or integrated
- Machine control Single or multiple equipment items
- Redundancy Duplicate X-Wave™ cores available for demanding applications
- Diagnostics Operator diagnostics and data logging
- Remote support Remote access through vessel VSAT
- Deployment OEM/new equipment, retrofit and portable applications
Share your equipment, vessel, actuator and operating requirements with MJR.
Motion Compensation
Projects
Explore projects demonstrating MJR's capability in electrical power conversion, vessel integration, energy storage and marine electrification.
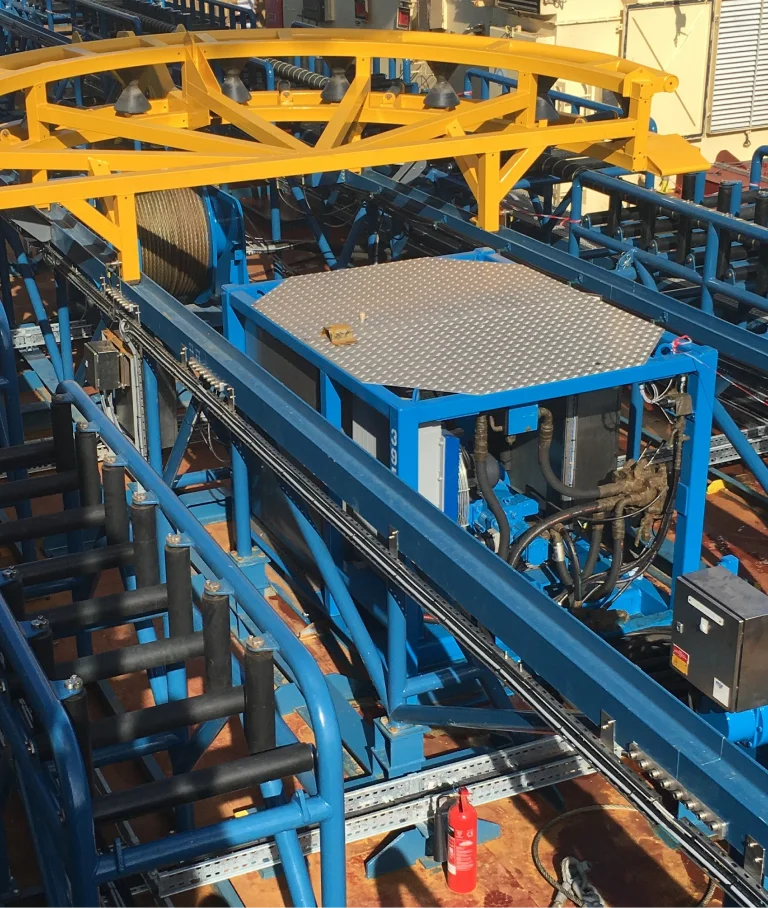
Deck Winch Constant Tension Control Upgrade & Reactivation
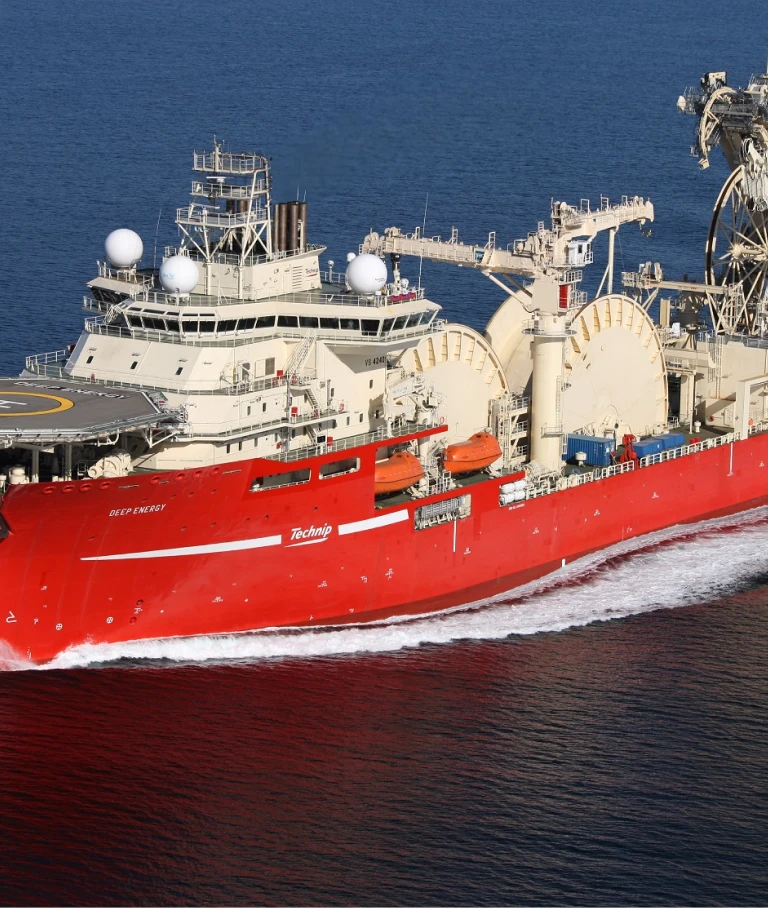
Deck Winch Constant Tension Control Upgrade for Deep Energy
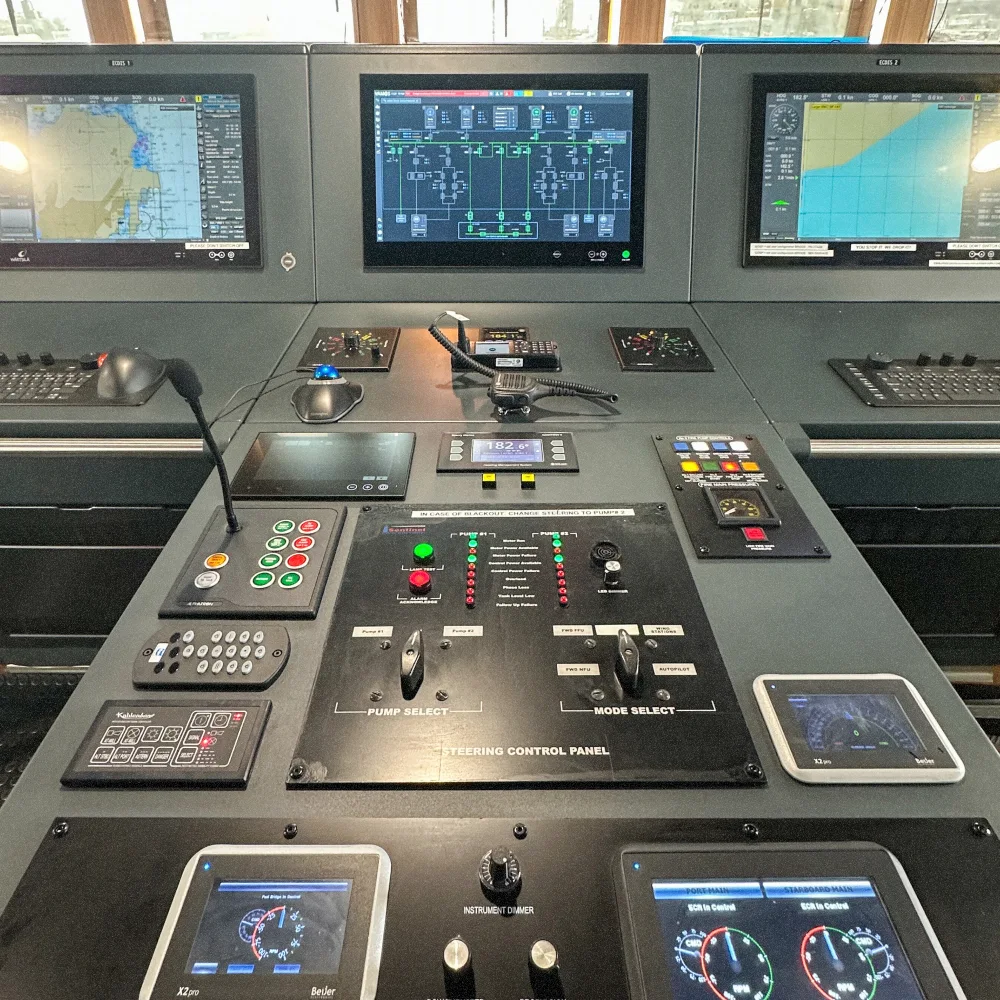
VAMOS the marine automation platform for vessel control, alarms, monitoring, power management and operational visibility.
Offshore vessel charging and power-transfer technology for offshore wind vessels and remote marine operations.
QuayPower™ shore power systems providing integrated shore-to-ship electrical power for vessels in ports and harbours.
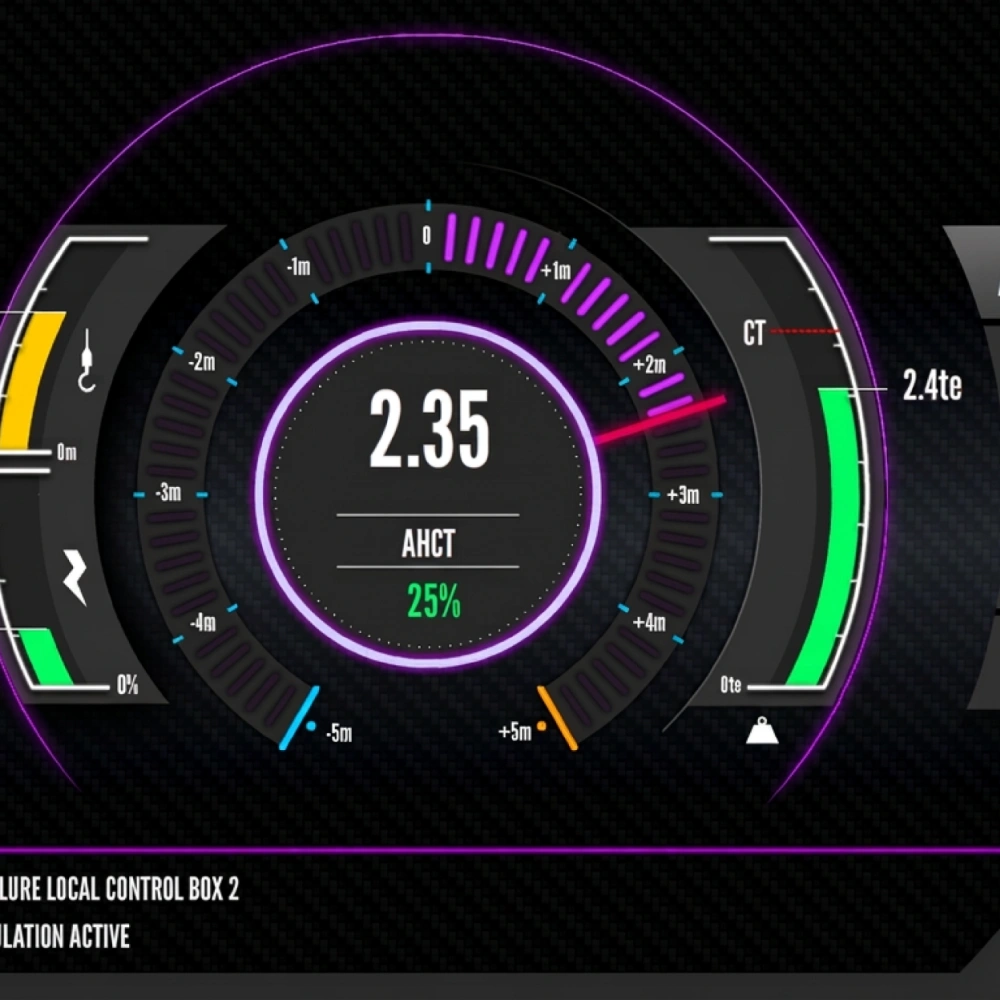
X-Wave™ active heave compensation technology for offshore lifting, launch and recovery, and subsea operations.
The Questions We Get Asked Most
Find answers to common questions about X-Wave™ Motion Compensation, including Active Heave Compensation, supported machinery and actuator types, operating modes, retrofit integration, self-learning configuration, redundancy and remote technical support.